Skip to content

Open to research roles

Nadil Gunawardane

Robotics researcher. I work on vision-language-action models, reinforcement learning and physical AI.

University of Moratuwa Ex-research intern, NUS MARMoT Lab Sri Lanka

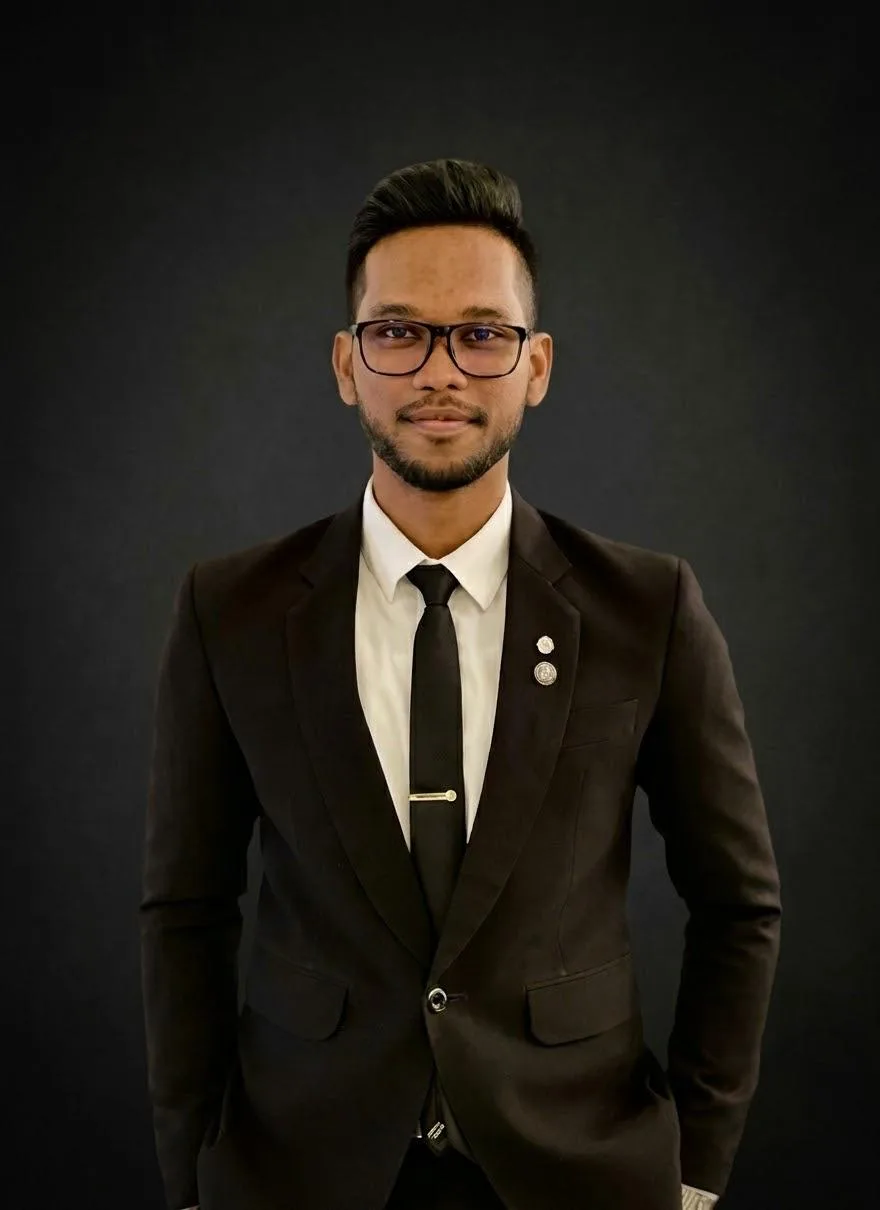
Portrait of Nadil Gunawardane

Selected work

Research and academic projects. Paper reproductions, SLAM and a robot built from scratch.

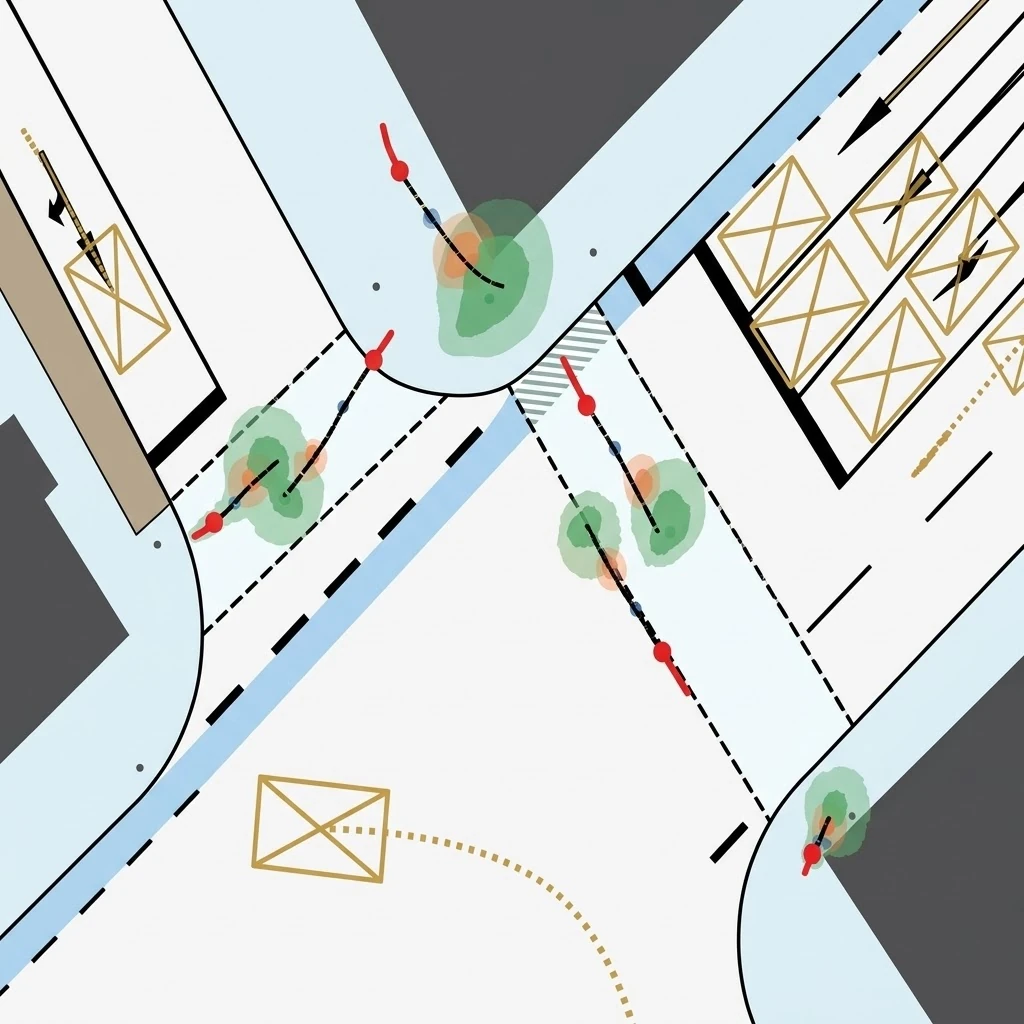
  • Top-down street crossing with predicted pedestrian paths and uncertainty clouds

    ECCV 2024 · Reproduction

    Probabilistic Human Trajectory Prediction

    Mixture density networks that forecast multimodal pedestrian trajectories with calibrated uncertainty, for autonomous applications that must plan around people.

    Python · PyTorch · MDNCode
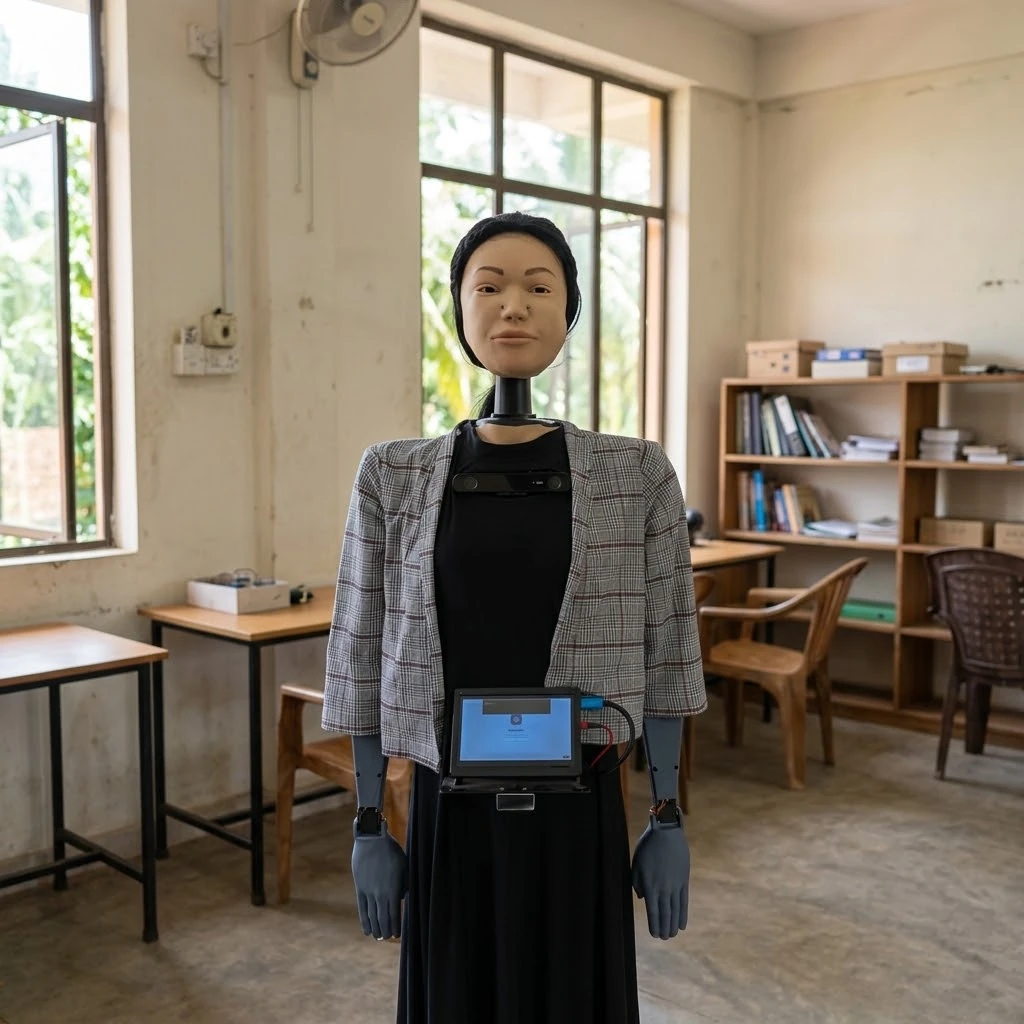
  • Semi-humanoid receptionist robot with a chest-mounted touchscreen, standing in a lab

    Final-year project

    Mobile Robot Receptionist

    A semi-humanoid receptionist robot for crowded, multi-floor buildings that rides conventional elevators without any robot-specific hardware.

    Mobile robotics · Navigation · HRIReport
  • EKF-SLAM plot: the robot's path around a circular cone track, with 3-sigma uncertainty ellipses shrinking as cones are mapped

    Autonomous racing

    Feature-Based EKF-SLAM

    Landmark-based Extended Kalman Filter SLAM for a differential-drive robot navigating cone-marked race tracks, mapping and localizing simultaneously.

    MATLAB · EKF · SLAMCode
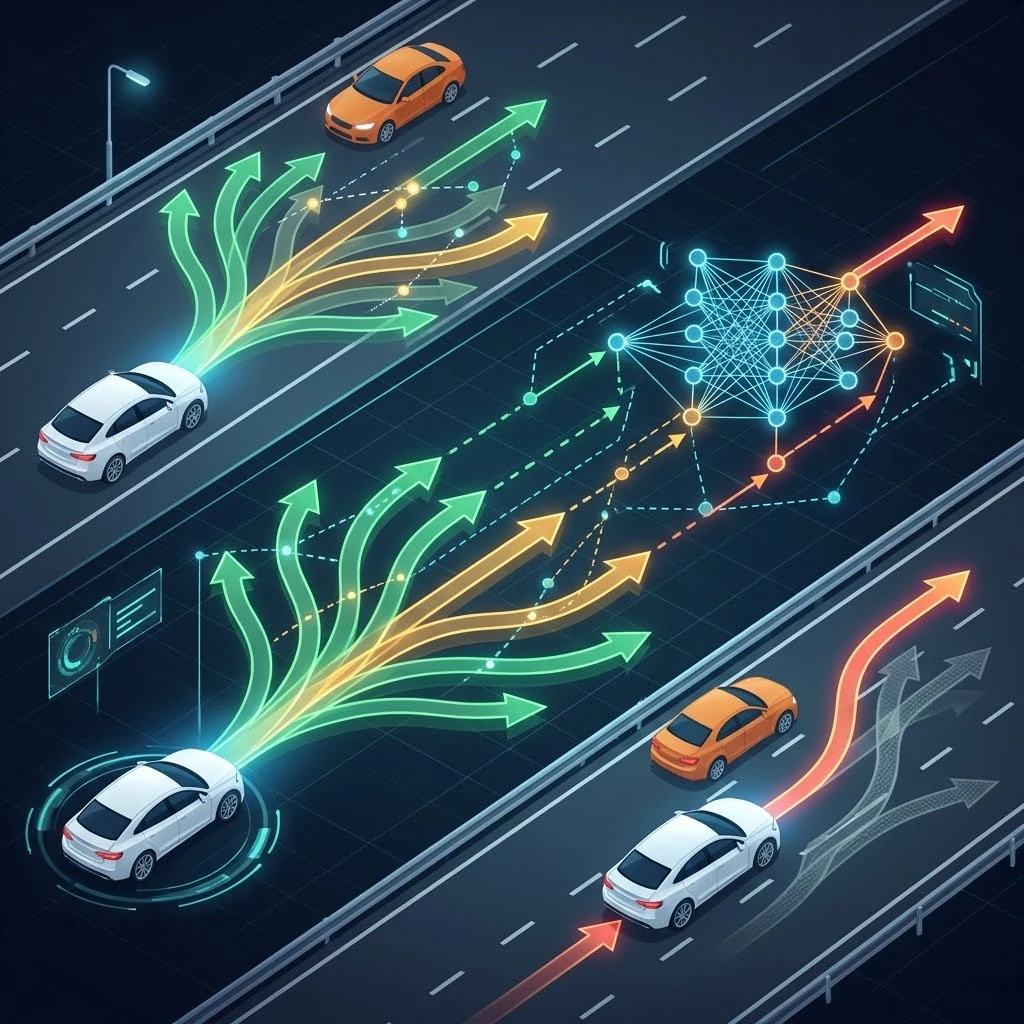
  • Cars on a highway with fans of candidate trajectories feeding a planning network

    CVPR 2025 · Implementation

    MomAD: Momentum-Aware Planning

    Paper implementation of momentum-aware planning for end-to-end autonomous driving, keeping planned trajectories temporally consistent.

    Python · PyTorch · End-to-end ADCode
  • Team Quanta's micromouse, a compact green PCB robot with side-facing IR sensors, resting on Robofest 2024 certificates

    Robofest 2024 · 5th place

    Quanta Micromouse

    Team Quanta's maze-solving robot. It completed the 16×16 maze at SLIIT Robofest 2024 and placed 5th in the university category, using flood fill on an STM32 with PID loops for distance and heading fed by IR, gyro and encoder readings.

    STM32 · C · PID · Flood fillCode

Research experience

Where I've done research. Robotics labs and drone R&D.

  1. Dec 2024 to May 2025

    Singapore

    Research Intern

    National University of Singapore · MARMoT Laboratory

    • Designed, developed and validated bespoke printed circuit boards for lab robot platforms.
    • Built and tested robot control systems as part of ongoing robotics and automation research.
    • Worked alongside graduate researchers and staff, trading ideas across hardware and software.

    PCB design · Robot control · Embedded systems · Research

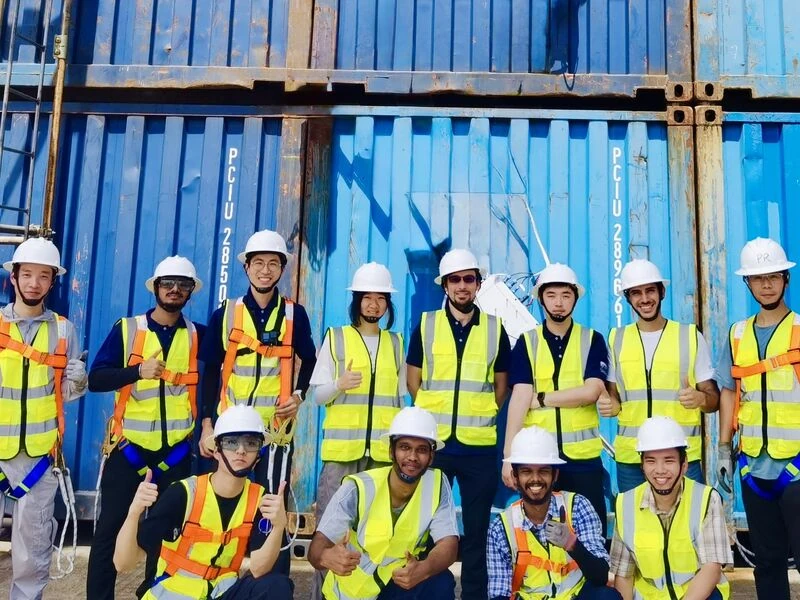
    The MARMoT Laboratory team in hard hats and high-visibility vests, posing in front of shipping containers
  2. Dec 2023 to Sep 2024

    Sri Lanka

    Research Associate

    Qubebots · Xfly drone platform

    • Researched camera-based localization for the Xfly drone using the onboard embedded camera.
    • Built a battery state and flight-time estimation system from calibrated voltage measurements.

    Computer vision · Drones · Localization · Embedded

Contact

Get in touch. I would welcome the chance to contribute to your research.

If your lab or team works on VLA models, reinforcement learning or physical AI, I would be grateful to hear about any research positions or collaborations. Please feel free to write to me.