ECCV 2024 · Reproduction
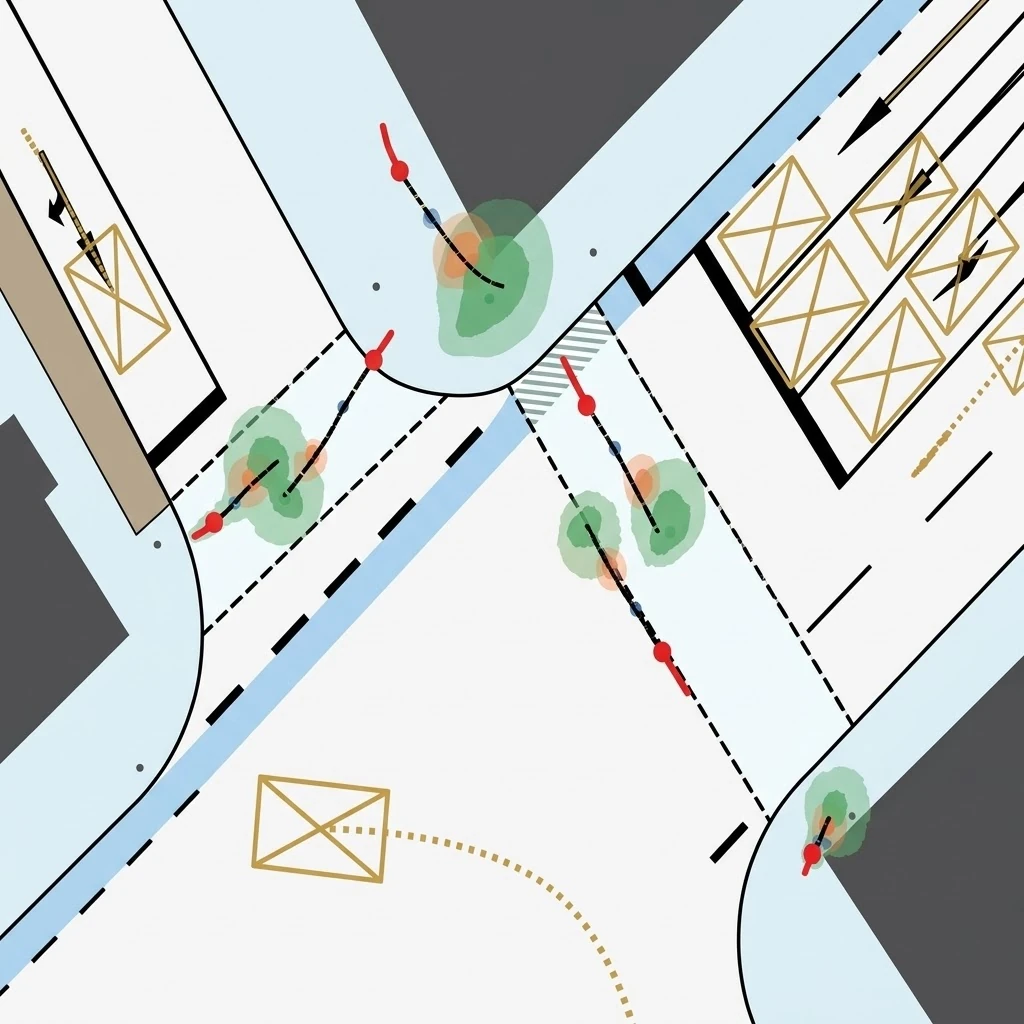
Probabilistic Human Trajectory Prediction
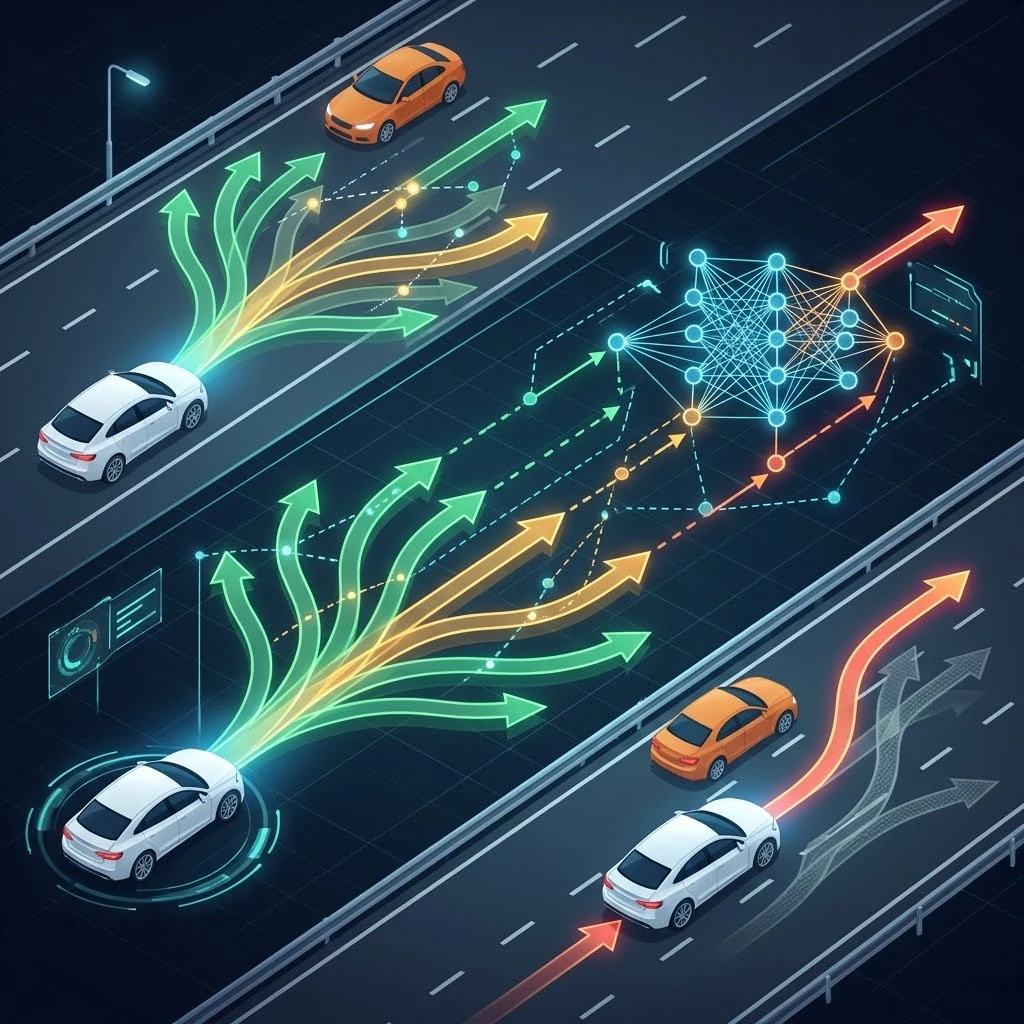
Mixture density networks that forecast multimodal pedestrian trajectories with calibrated uncertainty, for autonomous applications that must plan around people.
Projects
Every project links to its code on GitHub. Filter by area, or scroll down for older and smaller projects.

ECCV 2024 · Reproduction
Mixture density networks that forecast multimodal pedestrian trajectories with calibrated uncertainty, for autonomous applications that must plan around people.

Final-year project
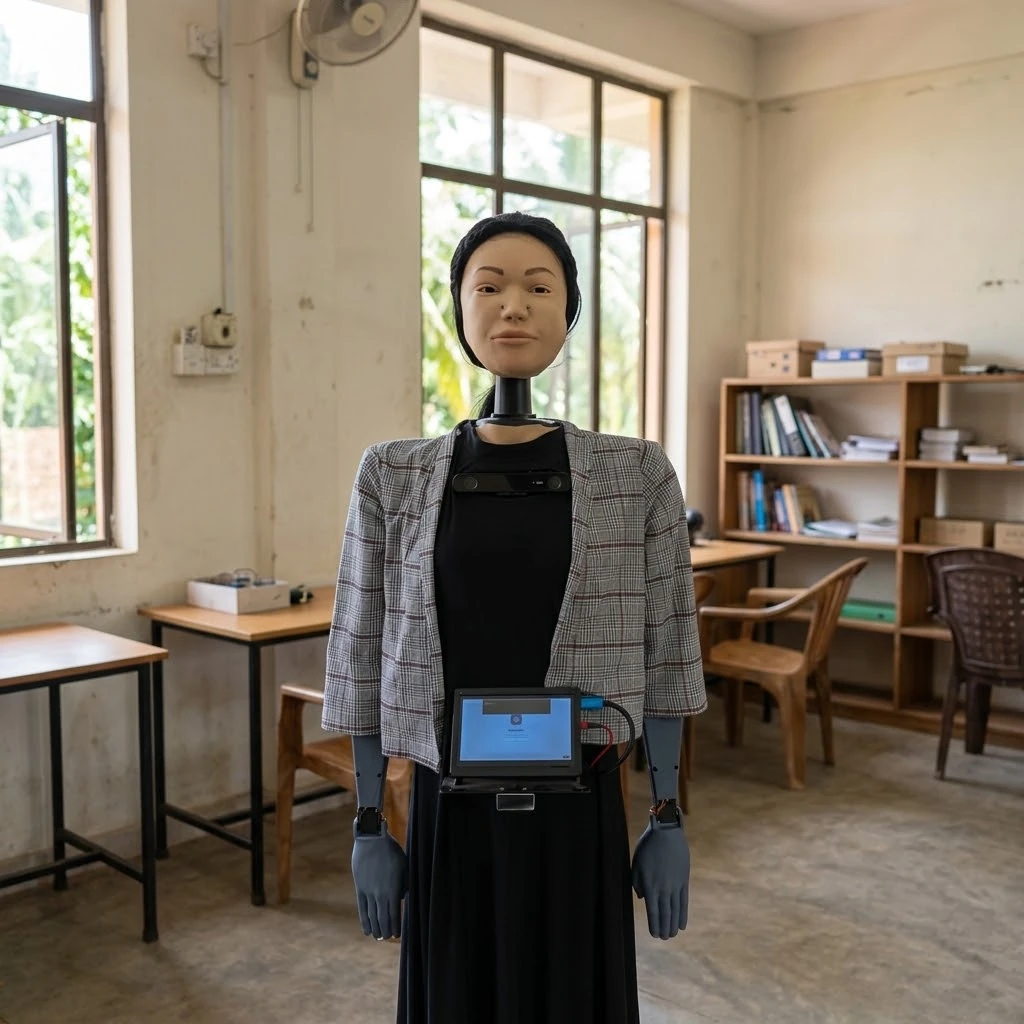
A semi-humanoid receptionist robot for crowded, multi-floor buildings that rides conventional elevators without any robot-specific hardware.

Autonomous racing
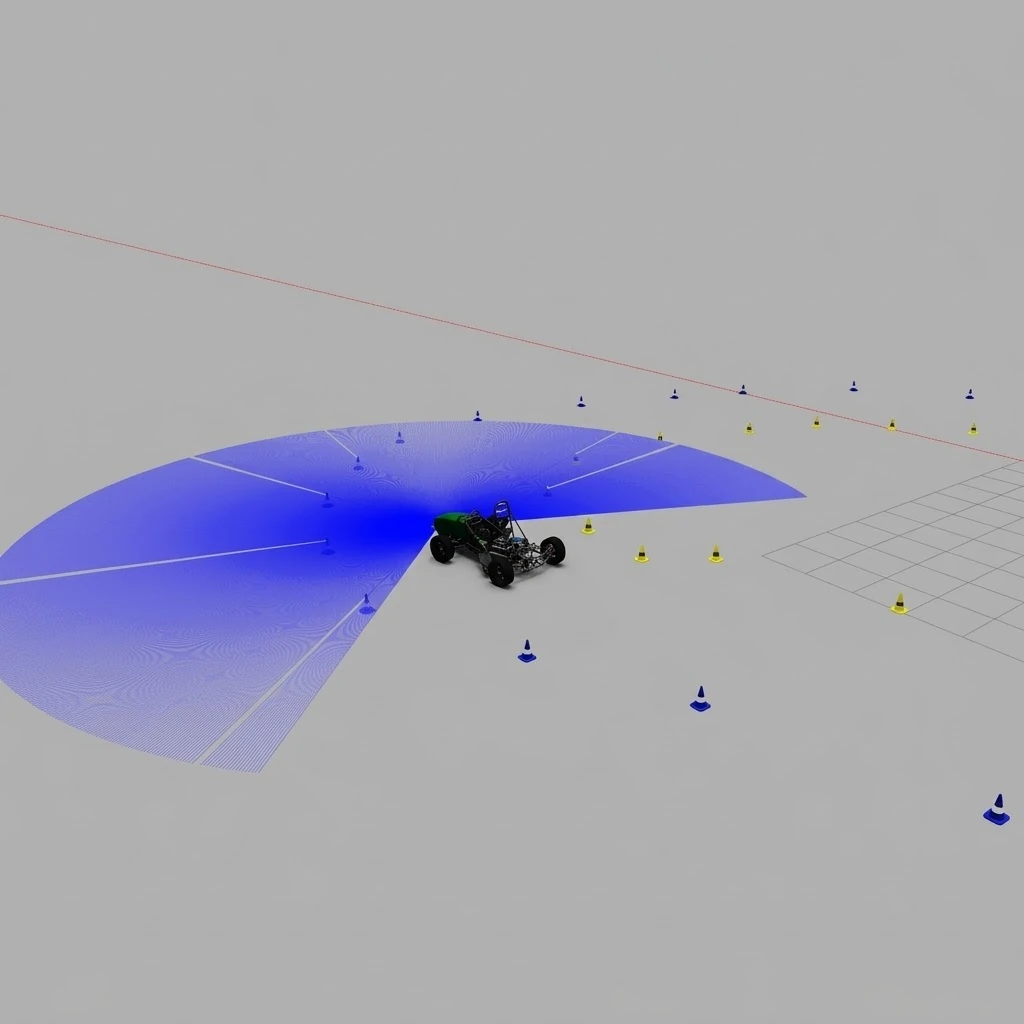
Landmark-based Extended Kalman Filter SLAM for a differential-drive robot navigating cone-marked race tracks, mapping and localizing simultaneously.

CVPR 2025 · Implementation
Paper implementation of momentum-aware planning for end-to-end autonomous driving, keeping planned trajectories temporally consistent.

Robofest 2024 · 5th place
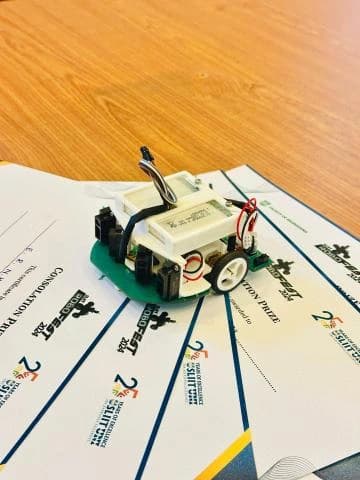
Team Quanta's maze-solving robot. It completed the 16×16 maze at SLIIT Robofest 2024 and placed 5th in the university category, using flood fill on an STM32 with PID loops for distance and heading fed by IR, gyro and encoder readings.

Autonomous racing
Labs and implementations from the F1Tenth course, covering autonomous racing, ROS 2, control algorithms and sensor integration for 1:10 scale race cars.

Qubebots
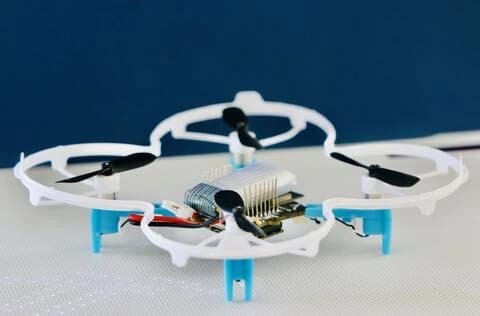
Localizing a drone platform in real time from its embedded camera feed to improve navigation accuracy.

Kinematics
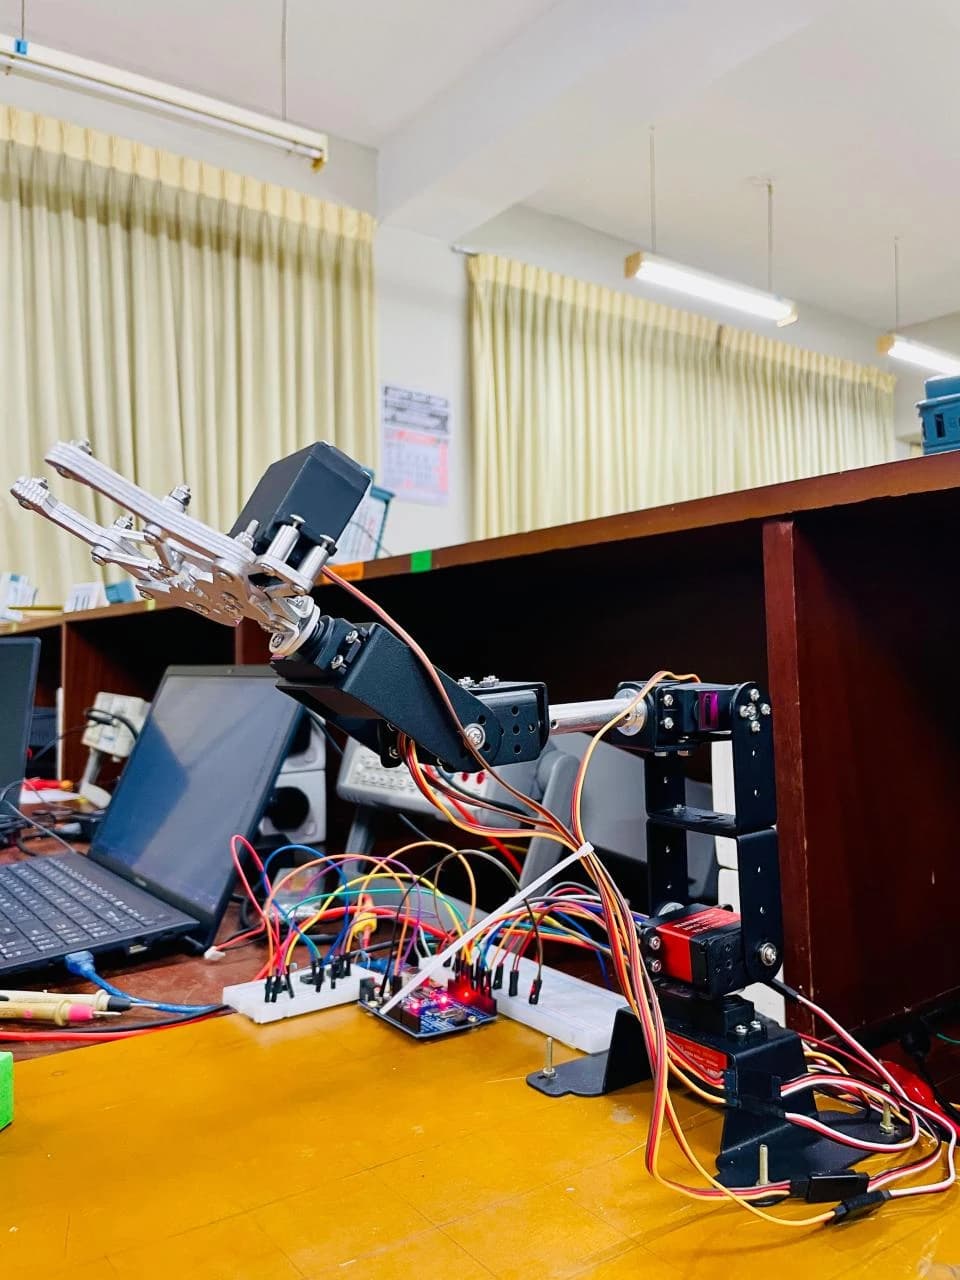
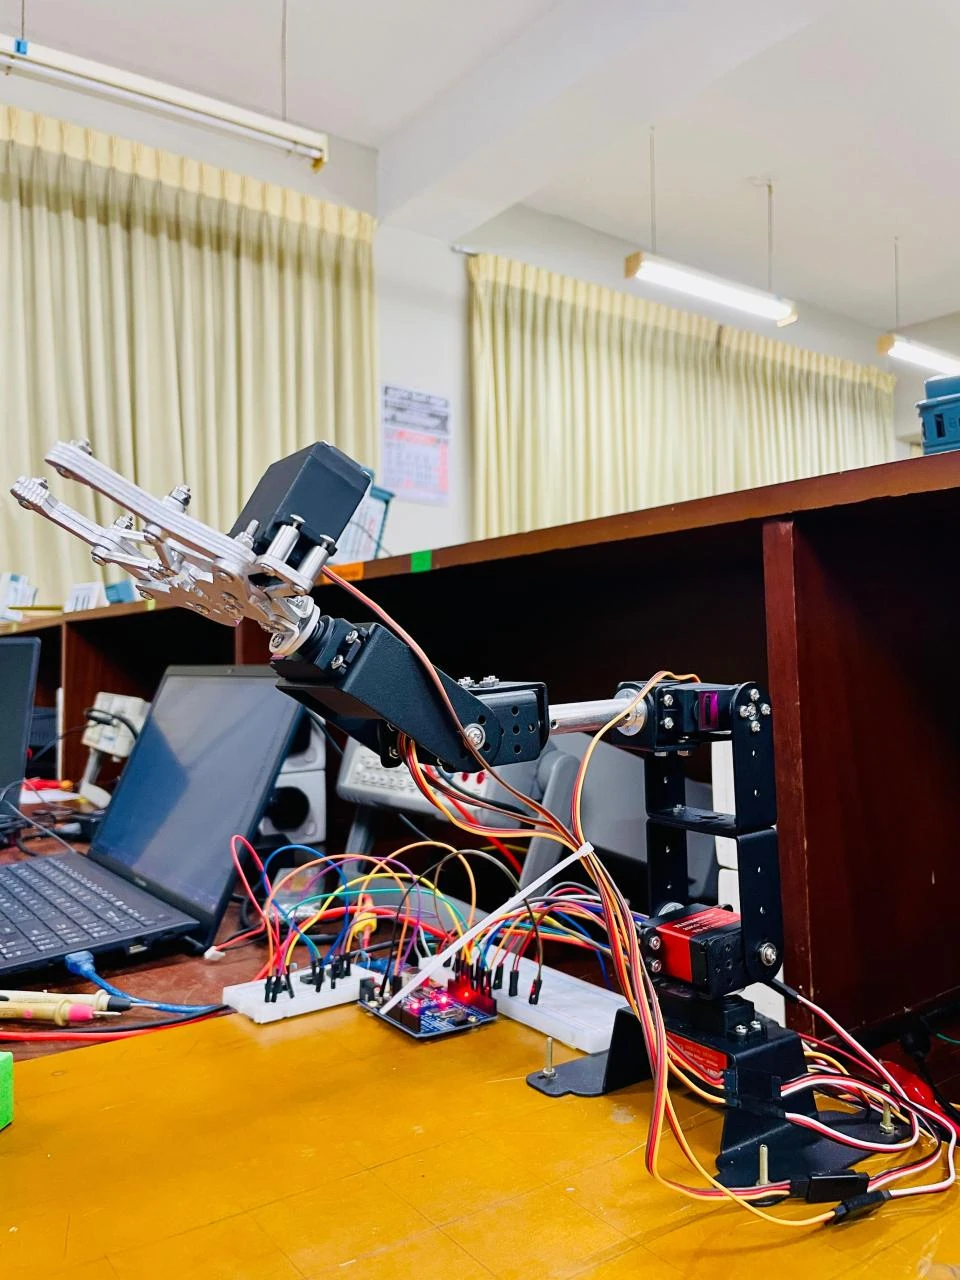
Forward and inverse kinematics for a 5-DOF arm using Denavit-Hartenberg parameters, with end-effector pose computation.

Assistive tech
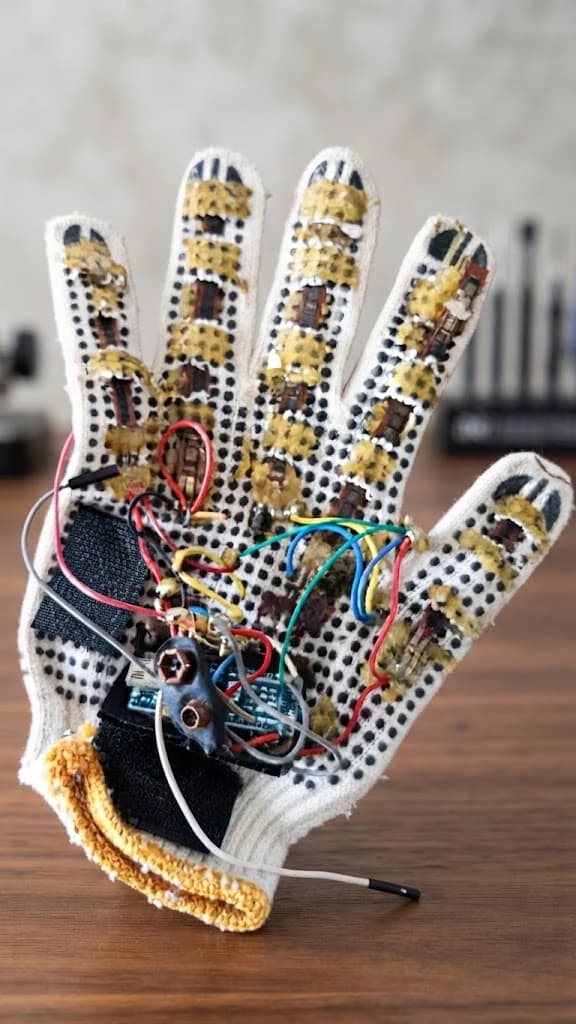
A sensor-embedded glove that recognises hand gestures, helping speech-disabled people communicate more easily.

Qubebots
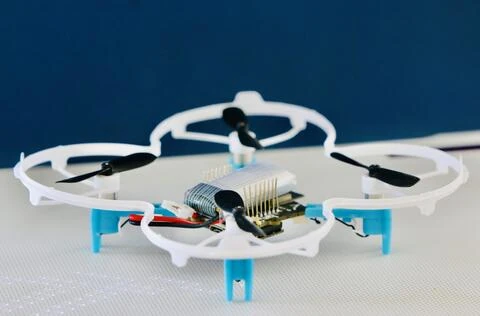
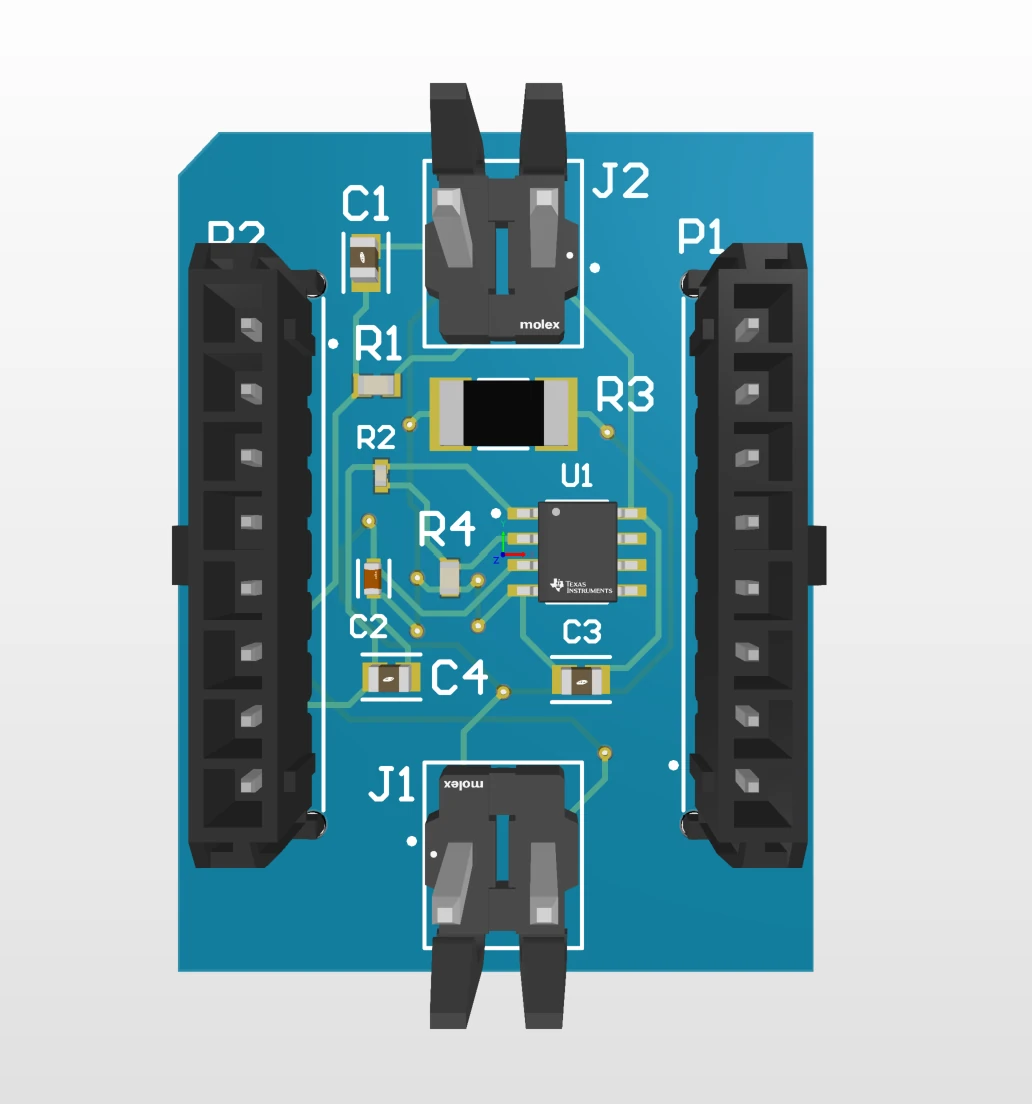
Accurate battery percentage and remaining flight-time estimation for the Xfly drone from calibrated voltage readings.
Contact
If your lab or team works on VLA models, reinforcement learning or physical AI, I would be grateful to hear about any research positions or collaborations. Please feel free to write to me.